Skip to content
Machine Learning and Positioning Systems
Home
Team
Application Guidelines
Publications
Research
Research Projects
Datasets
Teaching
Thesis
Student Projects
Courses
RL@FAU2025
RL@FAU2024
RL@FAU2023
RL@FAU2022
RL@FAU2021
RL@LMU2020
DataFest: Tool-Tracking with Machine Learning
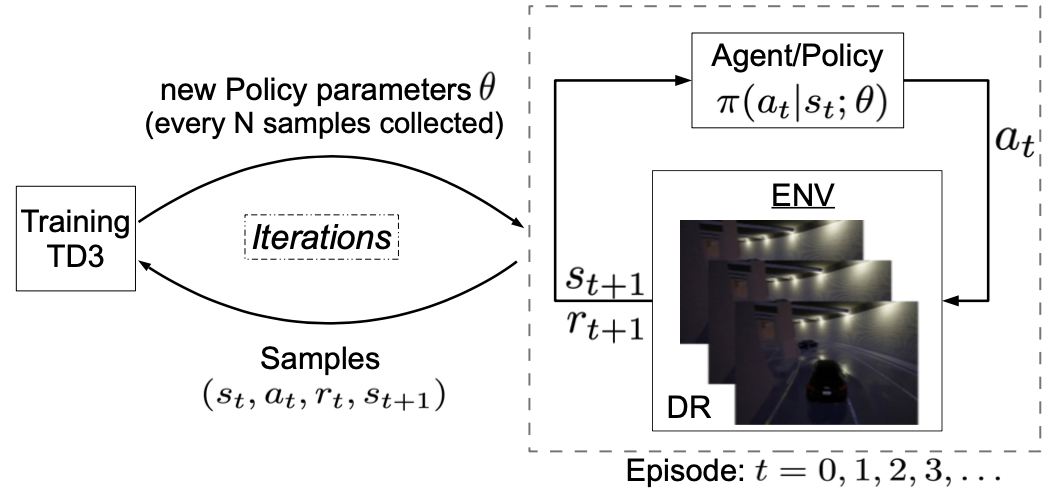
High-Speed Collision Avoidance using Deep Reinforcement Learning and Domain Randomization for Autonomous Vehicles
Scroll to Top