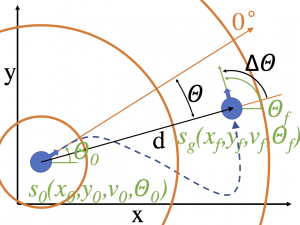
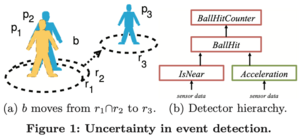
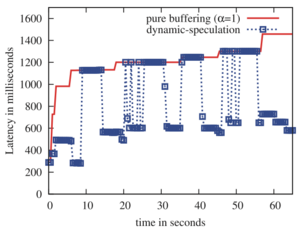
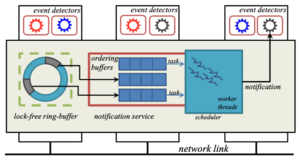
We show how deep learning (DL) can be used to estimate the position of mobile objects directly from the raw channel impulse responses (CIR) extracted at the receivers. Our experiments show that our DL-based position estimation not only works well under harsh multipath propagation but also outperforms state-of-the-art approaches in line-of-sight situations. We present a novel motion and trajectory planning algorithm for nonholonomic mobile robots that uses recent advances in deep reinforcement learning. Starting from a random initial state, i.e., position, velocity and orientation, the robot reaches an arbitrary target state while taking both kinematic and dynamic constraints into account. Our deep reinforcement learning agent not only processes a continuous state space it also executes continuous actions, i.e., the acceleration of wheels and the adaptation of the steering angle. We evaluate our motion and trajectory planning on a mobile robot with a differential drive in a simulation environment. We explore motion parameters, more specifically gait parameters, as an objective indicator to assess simulator sickness in Virtual Reality (VR). We used two different camera pose (position and orientation) estimation methods for the evaluation of motion tasks in a large-scale VR environment: a simple model and an optimized model that allows for a more accurate and natural mapping of human senses. The subjective measures from participants confirmed that the optimized pose estimation model reduces simulator sickness and increases the perceived presence. The results further show that both models affect the gait parameters and simulator sickness, which is why we further investigated a classification approach that deals with non-linear correlation dependencies between gait parameters and simulator sickness. This poster presents a novel type of Virtual Reality (VR) application for education and culture: a location-based VR Museum, which is a large-room scale multi-user multi-zone virtual museum. This VR museum was designed to support over 100 simultaneous users, walking in a large tracking system (600 m2) and sharing a ten times bigger virtual space (7000 m2) containing indoor and outdoor dinosaur exhibitions. This poster is giving an overview of the system and its main features as well as discussing its potential benefits and future evaluation. This paper presents a novel approach for the augmentation of social behaviors in virtual reality (VR) and designed three visual transformations for behavioral phenomena crucial to everyday social interactions: eye contact, joint attention, and grouping. We show that our results indicate that our approach can significantly increase social presence in multi-user environments and that the augmented experience appears more thought-provoking. We propose a signal processing method that uses deep learning to estimate the absolute tag position directly from the raw channel impulse response (CIR) data. We use the CIR together with ground truth positional data to train a convolutional neural network (CNN) that not only estimates non-linearities in the signal propagation space but also analyzes the signal for multipath effects. Our evaluation shows that our position estimation works in multipath environments and also outperforms classical signal processing in line-of-sight situations. This paper proposes evaluation criteria that consider algorithmic properties of ML-based positioning schemes and introduces a dataset from an indoor warehouse scenario to evaluate for them. Our dataset consists of images labeled with millimeter precise positions that allows for a better development and performance evaluation of learning algorithms. This allows an evaluation of machine learning algorithms for monocular optical positioning in a realistic indoor position application for the first time. We also show the feasibility of ML-based positioning schemes for an industrial deployment. Pose tracking does not yet reliably work in large-scale interactive multi-user VR. Our novel head orientation estimation combines a single inertial sensor located at the user’s head with inaccurate positional tracking. We exploit that users tend to walk in their viewing direction and classify head and body motion to estimate heading drift. This enables low-cost long-time stable head orientation. We evaluate our method and show that we sustain immersion. This paper studies the effects of head orientation drift around the yaw axis on the user’s absolute head and body orientations when walking naturally in the VR. We study how much drift accumulates over time, how a user experiences and tolerates it, and how a user applies strategies to compensate for larger drifts. We propose a novel positioning system which uses the entities of visible light communication (VLC) system as anchors and tags. Our technique scales with the number of tags and the VLC network provides both positioning and communication capabilities. The anchor points transmit the OFDM-based VLC signals synchronously, and we estimate the time differences of arrival between anchor points and tags using positioning reference signals embedded into the air-interface of the VLC system. Simulation results show that positioning accuracy of 10 cm or better is possible for over 95% of users if the sampling clock offset is better that 10 ppm, clock jitter is below 1 ps, and a bit resolution of at least 16 bits is available. We train recurrent neural networks on ToFs both in simulation and reality that successfully processes noisy measurements that are not zero-mean Gaussian distributed. We show that our methods outperforms conventional methods based on Kalman filters that are currently considered to be state of the art. We propose a methodology for building control. A central part of our methodology is the control improvement (or optimisation) module, facilitating two simulation-based control improvement methodologies: one based in multi-criteria decision analysis methods and the other based on state-space identification of dynamical systems using Gaussian process models and reinforcement learning. We evaluate the proposed methodology in a set of simulation-based experiments using the thermal simulation model of a real building located in Portugal. In this paper, a subspace-based approach to frequency-domain multipath resolution is presented. Resolution of multipath components allows for a RSS-based DOA estimation considering the power of the line of sight (LOS) component only. The impact of the multipath channel is considerably reduced with our approach. In contrast to common broadband DOA estimation techniques, the presented approach does not need phase-coherent receive channels or a synchronized sensor network. Hence, the proposed super-resolution technique is applicable to low-power sensor networks and brings accurate positioning to small-sized and energy-efficient sensor nodes. Our novel yaw orientation estimation combines a single inertial sensor located at the human’s head with inaccurate positional tracking. We exploit that humans tend to walk in their viewing direction and that they also tolerate some orientation drift. We classify head and body motion and estimate heading drift to enable low-cost long-time stable head orientation in NP tracking on 100 m×100 m. Our evaluation shows that we estimate heading reasonably well. Redirected Walking (RDW) manipulates a scene that is displayed to VR users so that they unknowingly compensate for scene motion and can thus explore a large virtual world on a limited space. So far, mostly visual manipulation techniques have been studied. This work in progress report demonstrates a novel approach for behavioral augmentations in Virtual Reality (VR). Using a large scale tracking system, groups of five users explored a virtual museum. We investigated how augmenting social interactions impacts this experience, by designing behavioral transformations for behavioral phenomena in social interactions. Preliminary data indicate a reduction of perceived isolation, and a more thought-provoking experience with active behavioral augmentations. Many satellite systems require knowledge about inter-satellite distances. Inter-satellite links provide direct connectivity between satellites and may be used for ranging, while they remove the need of dedicated hardware. This paper addresses inter-satellite ranging at the Low Earth Orbit (LEO) using S-Band signals. We take the requirements from recent missions and future applications into account and analyze the factors that limit ranging. We show how these factors affect the quality of distance estimation in terms of the Cramér-Rao Lower Bound for ranging. Two-way-ranging (TWR) provides the best accuracy and sustains the low-cost objective of small satellites. We further propose an enhanced TWR message exchange that enables on-the-fly delay calibration and sub-sample corrections. We implemented the transceiver modules on a Software-Defined Radio (SDR) platform and evaluated them with real-world data. The results show that the proposed ranging algorithm achieves an accuracy of few centimeters. We present a concept for energy-efficient low-complexity localization based on Phase Difference of Arrival (PDoA). Besides a novel method for reference transmitter selection we propose a waveform, well-suited for PDoA measurements, and evaluate its ranging performance. We compare multiple signal classification (MUSIC), linear fitting, and mean phase difference and compare their estimation variance to the Cramer Rao Lower Bound (CRLB). Our system concept allows for the mitigation of near-far effects for reference and tag signals at the receiver nodes, and an efficient implementation of a wideband frequency hopping scheme. We conducted an online survey among 227 athletes about the acceptance of virtual reality headsets for training in different kind of sport disciplines. We present an adaptive speculative processing technique for out-of-order event streams that enhances typical buffering approaches. Our novel technique encapsulates the event detector, uses the buffering technique to delay events but also speculatively processes a portion of it, and adapts the degree of speculation at runtime to fit the available system resources so that detection latency becomes minimal. Our technique outperforms known approaches on both synthetical data and real sensor data from a realtime locating system (RTLS) with several thousands of out-of-order sensor events per second. Speculative buffering exploits system resources and reduces latency by 40% on average. The DEBS 2014 Grand Challenge targets the monitoring and prediction of energy loads of smart plugs installed in private households. This paper presents details of our middleware solution and efficient median calculation, shows how we address data quality issues, and provides insights into our enhanced prediction based on hidden Markov models. We present a low-latency approach based on K-slack that achieves ordered event processing on high data rate sensor and event streams without a-priori knowledge. Slack buffers are dynamically adjusted to fit the disorder in the streams without using local or global clocks. The middleware transparently reorders the event input streams so that events can still be aggregated and processed to a granularity that satisfies the demands of the application. On a Realtime Locating System (RTLS) our system performs accurate low-latency event detection under the predominance of out-of-order event arrival and with a close to linear performance scale-up when the system is distributed over several threads and machines.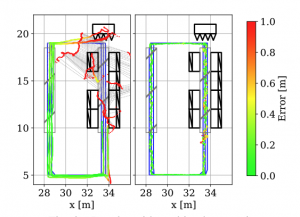
A Deep Learning Approach to Position Estimation from Channel Impulse Responses
Deep Reinforcement Learning for Motion Planning of Mobile Robots
Sick Moves! Motion Parameters as Indicators of Simulator Sickness
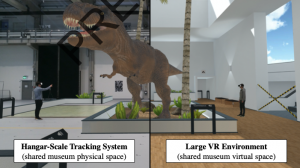
A Location-Based VR Museum
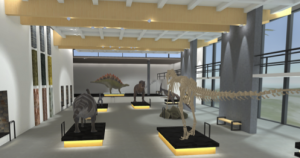
Beyond Replication: Augmenting Social Behaviors in Multi-User Virtual Realities
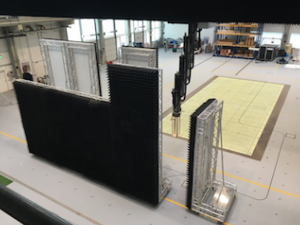
Convolutional Neural Networks for Position Estimation in TDoA-based Locating Systems
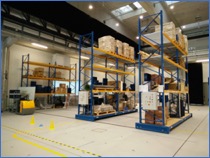
Evaluation Criteria for Inside-Out Indoor Positioning Systems based on Machine Learning
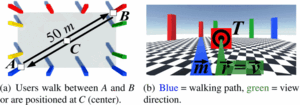
Head-to-Body-Pose Classification in No-Pose VR Tracking Systems
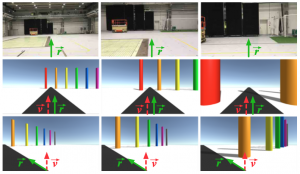
Human Compensation Strategies for Orientation Drifts
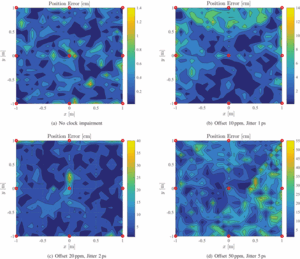
Indoor Positioning using OFDM-based Visible Light Communications Systems
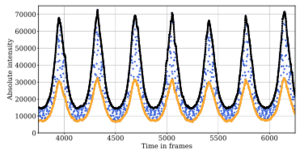
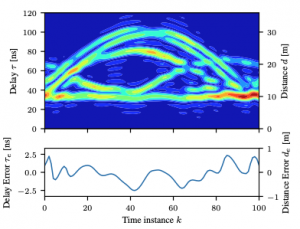
Recurrent Neural Networks on Drifting Time-of-Flight Measurements
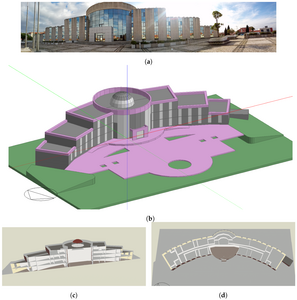
Simulation-based Evaluation and Optimization of Control Strategies in Buildings
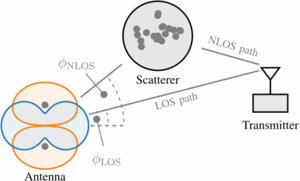
Super-Resolution in RSS-based Direction-of-Arrival Estimation
Supervised Learning for Yaw Orientation Estimation
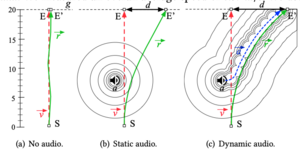
Acoustical Manipulation for Redirected Walking
This paper shows that users can also be manipulated by means of acoustical signals. In an experiment with a dynamically moving audio source we see deviations of up to 30% from a 20 m long straight-line walk for male participants and of up to 25% for females. Static audio has about two thirds of this impact.
Social Augmentations in Multi-User Virtual Reality: A Virtual Museum Experience
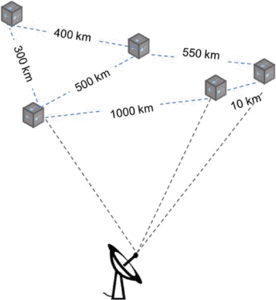
Inter-Satellite Ranging in the Low Earth Orbit
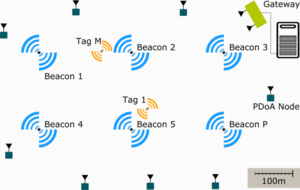
Low-Complexity PDoA-based Localization
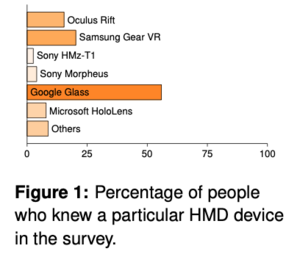
Virtual and Augmented Reality in Sports: An Overview and Acceptance Study
Adaptive Speculative Processing of Out-of-Order Event Streams
Predictive Load Management in Smart Grid Environments
The evaluation on the smart grid data set shows that we process up to 244k input events per second with an average detection latency of only 13.3ms, and that our system efficiently scales across nodes to increase throughput. Our prediction model significantly outperforms the median-based prediction as it deviates much less from the real load values, and as it consumes considerably less memory.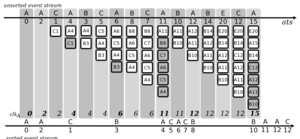
Distributed Low-Latency Out-of-Order Event Processing for High Data Rate Sensor Streams