Selected Publications



All Publications
‹ Previous 1 … 5 6 7 8 9 Next ›
A sense of quality for augmented reality assisted process guidance
We develop a Machine Learning (ML) classifier that predicts quality metrics from a 9-degrees of freedom inertial measurement unit, while we simultaneously guide and track the work processes with a HoloLens AR system. In our user study, 6 test subjects perform typical assembly tasks with our system. We evaluate the tracking accuracy of the system based on a precise optical reference system and evaluate the classification of each work step quality based on the collected ground truth data. Our evaluation shows a tracking accuracy of fast dynamic movements of 4.92mm and our classifier predicts the actions carried out with mean F1 value of 93.8% on average.
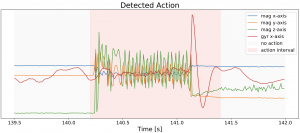
Automated Quality Assurance for Hand-held Tools via Embedded Classification and AutoML
We introduce a process monitoring system that uses inertial, magnetic field and audio sensors that we attach as add-ons to hand-held tools. The sensor data is analyzed via embedded classification algorithms and our system directly provides feedback to workers during the execution of work processes. We outline the special requirements caused by vastly different tools and show how to automatically train and deploy new ML models.
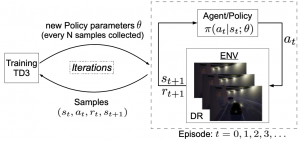
High-Speed Collision Avoidance using Deep Reinforcement Learning and Domain Randomization for Autonomous Vehicles
We use domain randomization to study simulation-to-reality transfer for a high-speed collision avoidance scenario. We train the policy not only on a single version of the setup but on several variations. Our experiments show that the resulting policy is able to generalize much better to different values for the vehicle speed and distance from the obstacle compared to policies trained in the non-randomized version of the setup.
Video: https://download.cmutschler.de/publications/2020/ITSC/0703_VP.mp4
Slides: https://download.cmutschler.de/publications/2020/ITSC/0703_PS.pdf
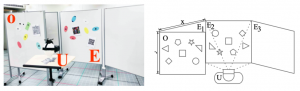
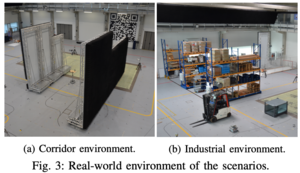
Localization Limitations of ARCore, ARKit, and Hololens in Dynamic Large-Scale Industry Environments
We study the applicability of today’s popular AR systems (Apple ARKit, Google ARCore, and Microsoft Hololens) in an industrial context (large area of 1,600m2, long walking distances of 60m between cubicles, and dynamic environments with volatile natural features). Out of the box, these AR systems are far from useful even for normal motion behavior. They accumulate an average error of about 17m per 120m, with a scaling error of up to 14.4cm/m that is quasi-directly proportional to the path length. By adding natural features, the tracking reliability can be improved, but not enough.
NLOS Detection using UWB Channel Impulse Responses and Convolutional Neural Networks
We apply different convolutional neural network architectures (ResNet, Encoder, FCN) to detect non line-of-sight (NLOS) channel conditions directly from the CIR raw data. A realistic measurement campaign is used to train and evaluate the algorithms. The proposed methods highly outperform the featurebased ML baselines while still using low network complexities. We also show that the models generalize well to unknown receivers and environments and that positioning filters benefit significantly from the identification of NLOS measurements.
Real-time gait reconstruction for virtual reality using a single sensor
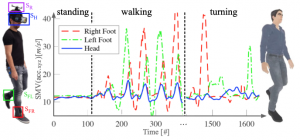
We propose an approach to reconstruct gait motions from a single head-mounted accelerometer. We train our models to map head motions to corresponding ground truth gait phases. To reconstruct leg motion, the models predict gait phases to trigger equivalent synthetic animations. We designed four models: a threshold-based, a correlation-based, a Support Vector Machine (SVM) -based and a bidirectional long-term short-term memory (BLSTM) -based model. Our experiments show that, while the BLSTM approach is the most accurate, only the correlation approach runs on a mobile VR system in real time with sufficient accuracy. Our user study with 21 test subjects examined the effects of our approach on simulator sickness and showed significantly less negative effects on disorientation.
RNN-aided Human Velocity Estimation from a Single IMU
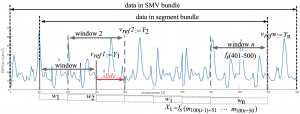
We propose a hybrid filter that combines a convolutional neural network (CNN) and a bidirectional recurrent neural network (BLSTM) (that extract spatial features from the sensor signals and track their temporal relationships) with a linear Kalman filter (LKF) that improves the velocity estimates. Our experiments show the robustness against different movement states and changes in orientation, even in highly dynamic situations. It also generalizes well to different and varying movement speeds and provides accurate and precise velocity estimates.
The OnHW Dataset: Online Handwriting Recognition from IMU-Enhanced Ballpoint Pens with Machine Learning
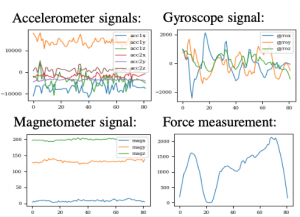
We propose a novel online handwriting dataset acquired from 119 writers consisting of 31,275 uppercase and lowercase English alphabet character recordings (52 classes) as part of the UbiComp 2020 Time Series Classification Challenge. Our novel OnHW-chars dataset allows for the evaluations of uppercase, lowercase and combined classification tasks, on both writer-dependent (WD) and writer-independent (WI) classes and we show that properly tuned machine learning pipelines as well as deep learning classifiers (such as CNNs, LSTMs, and BiLSTMs) yield accuracies up to 90 % for the WD task and 83 % for the WI task for uppercase characters.

ViPR: Visual-Odometry-aided Pose Regression for 6DoF Camera Localization
We propose ViPR, a novel modular architecture for longterm 6DoF VO that leverages temporal information and synergies between absolute pose estimates (from PoseNet-like modules) and relative pose estimates (from FlowNet-based modules) by combining both through recurrent layers. Experiments on known datasets and on our own Industry dataset show that our modular design outperforms state of the art in long-term navigation tasks.

A Bidirectional LSTM for Estimating Dynamic Human Velocities from a Single IMU
We ML/DL to estimate a human velocity. Our approach is robust to varying motion states and orientation changes in dynamic situations. On data from a single un-calibrated IMU, our novel recurrent model not only outperforms the state-of-the-art on instantaneous velocity (≤0.10 m/s) and on traveled distance (≤29 m/km). It can also generalize to different and varying rates of motion and provides accurate and precise velocity estimates.
A Deep Learning Approach to Position Estimation from Channel Impulse Responses
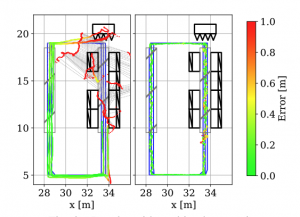
We show how deep learning (DL) can be used to estimate the position of mobile objects directly from the raw channel impulse responses (CIR) extracted at the receivers. Our experiments show that our DL-based position estimation not only works well under harsh multipath propagation but also outperforms state-of-the-art approaches in line-of-sight situations.
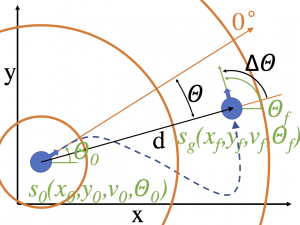
Deep Reinforcement Learning for Motion Planning of Mobile Robots
We present a novel motion and trajectory planning algorithm for nonholonomic mobile robots that uses recent advances in deep reinforcement learning. Starting from a random initial state, i.e., position, velocity and orientation, the robot reaches an arbitrary target state while taking both kinematic and dynamic constraints into account. Our deep reinforcement learning agent not only processes a continuous state space it also executes continuous actions, i.e., the acceleration of wheels and the adaptation of the steering angle. We evaluate our motion and trajectory planning on a mobile robot with a differential drive in a simulation environment.
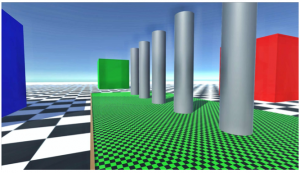
Sick Moves! Motion Parameters as Indicators of Simulator Sickness
We explore motion parameters, more specifically gait parameters, as an objective indicator to assess simulator sickness in Virtual Reality (VR). We used two different camera pose (position and orientation) estimation methods for the evaluation of motion tasks in a large-scale VR environment: a simple model and an optimized model that allows for a more accurate and natural mapping of human senses. The subjective measures from participants confirmed that the optimized pose estimation model reduces simulator sickness and increases the perceived presence. The results further show that both models affect the gait parameters and simulator sickness, which is why we further investigated a classification approach that deals with non-linear correlation dependencies between gait parameters and simulator sickness.
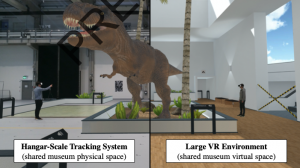
A Location-Based VR Museum
This poster presents a novel type of Virtual Reality (VR) application for education and culture: a location-based VR Museum, which is a large-room scale multi-user multi-zone virtual museum. This VR museum was designed to support over 100 simultaneous users, walking in a large tracking system (600 m2) and sharing a ten times bigger virtual space (7000 m2) containing indoor and outdoor dinosaur exhibitions. This poster is giving an overview of the system and its main features as well as discussing its potential benefits and future evaluation.
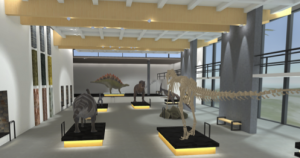
Beyond Replication: Augmenting Social Behaviors in Multi-User Virtual Realities
This paper presents a novel approach for the augmentation of social behaviors in virtual reality (VR) and designed three visual transformations for behavioral phenomena crucial to everyday social interactions: eye contact, joint attention, and grouping. We show that our results indicate that our approach can significantly increase social presence in multi-user environments and that the augmented experience appears more thought-provoking.