Selected Publications



All Publications
‹ Previous 1 … 3 4 5 6 7 … 9 Next ›
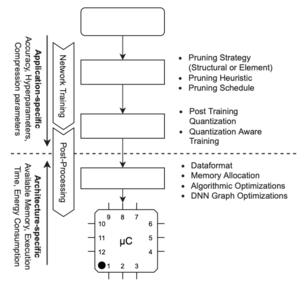
Energy-Efficient Deployment of Deep Learning Applications on Cortex-M based Microcontrollers using Deep Compression
We present a methodology for systematically exploring different DNN pruning, quantization, and deployment strategies for different microcontroller architectures, with a focus on lowpower ARM Cortex-M-based systems. The exploration allows to analyze trade-offs between key metrics such as accuracy, memory consumption, execution time, and power consumption. We discuss experimental results on three different DNN architectures and show that we can compress them to less than 10% of their original parameter count before their prediction quality degrades.
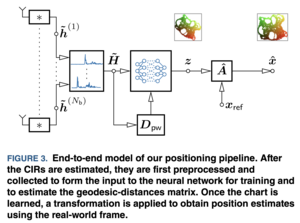
Indoor Localization with Robust Global Channel Charting: A Time-Distance-Based Approach
We propose a novel distance metric for CC that approaches a global linear correlation to the physical distance based on time-synchronized single-input/single-output (SISO) CSIs. This allows to learn the environment’s global geometry in a channel chart without annotations.
Dataset here: https://www.iis.fraunhofer.de/en/ff/lv/dataanalytics/pos/fingerprinting-dataset-for-positioning.html
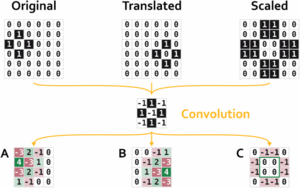
Just a Matter of Scale? Reevaluating Scale Equivariance in Convolutional Neural Networks
We propose the novel Scaled and Translated Image Recognition (STIR) benchmark based on four different domains. Additionally, we introduce a new family of models that applies many re-scaled kernels with shared weights in parallel and then selects the most appropriate one. Our experimental results on STIR show that both the existing and proposed approaches can improve generalization across scales compared to standard convolutions. We also demonstrate that our family of models is able to generalize well towards larger scales and improve scale equivariance. Moreover, due to their unique design we can validate that kernel selection is consistent with input scale. Even so, none of the evaluated models maintain their performance for large differences in scale, demonstrating that a general understanding of how scale equivariance can improve generalization and robustness is still lacking.
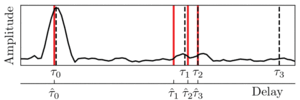
Multipath delay estimation in complex environments using transformer
We propose an MPC delay estimation pipeline based on a Transformer (TF) neural network, which implicitly estimates the number and delays of the MPCs. We achieve subsample accuracy without using computational expensive super-resolution techniques. Our approach outperforms state-of-the art on detection and delay estimation of MPCs on different bandwidths. We also show that our approach can easily be fine-tuned on real world data with very few labeled data samples, making it a well-suited candidate for real world deployments.
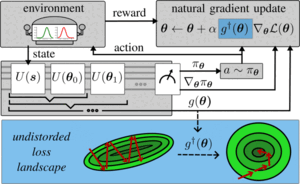
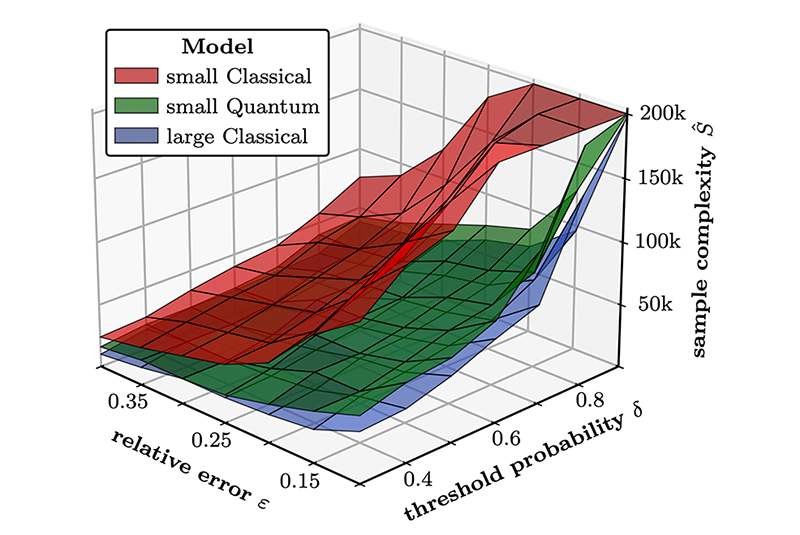
Quantum Natural Policy Gradients: Towards Sample-Efficient Reinforcement Learning
We propose the quantum natural policy gradient (QNPG) algorithm – a second-order gradient-based routine that takes advantage of an efficient approximation of the quantum Fisher information matrix. We experimentally demonstrate that QNPG outperforms first-order based training on different Contextual Bandits environments regarding convergence speed and stability and moreover reduces the sample complexity. Furthermore, we provide evidence for the practical feasibility of our approach by training on a 12-qubit hardware device.
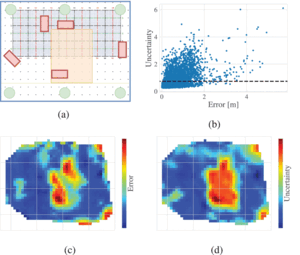
Uncertainty-based fingerprinting model selection for radio localization
In this paper we propose methods for uncertainty estimation of AI-based fingerprinting to determine its validity. Our experiments show that we can implicitly switch between classic and fingerprinting-based approaches to reliably estimate accurate positions, even in NLoS-dominated radio environments. Our approach works even if the AI models are only trained on radio data in certain areas of the environment. In contrast to the state-of-the-art, our approach intrinsically identifies the spatial boundaries of the AI model, and thus does not require prior area identification.
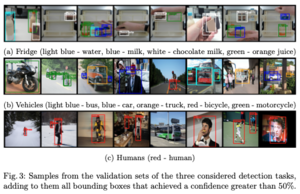
uYOLO: Towards Single-Shot Object Detection on Microcontrollers
This work-in-progress paper presents results on the feasibility of single-shot object detection on microcontrollers using YOLO. Single-shot object detectors like YOLO are widely used, however due to their complexity mainly on larger GPU-based platforms. We present YOLO, which can be used on Cortex-M based microcontrollers, such as the OpenMV H7 R2, achieving about 3.5 FPS when classifying 128128 RGB images while using less than 800 KB Flash and less than 350 KB RAM. Furthermore, we share experimental results for three different object detection tasks, analyzing the accuracy of YOLO on them.
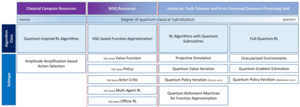
A Survey on Quantum Reinforcement Learning
We intend to provide a broad overview of the literature on quantum reinforcement learning and put particular emphasis on recent developments. With a focus on already available noisy intermediate-scale quantum devices, these include variational quantum circuits acting as function approximators in an otherwise classical reinforcement learning setting. We provide both a birds-eye-view of the field, as well as summaries and reviews for selected parts of the literature.
An Introduction to Multi-Agent Reinforcement Learning and Review of its Application to Autonomous Mobility
We give an overview of MARL to researchers in autonomous mobility. We first explain MARL and introduce important concepts. Then, we discuss the central paradigms that underlie MARL algorithms and give an overview of state-of-the-art methods and ideas in each paradigm. With this background, we survey applications of MARL in autonomous mobility scenarios and give an overview of existing scenarios and implementations.
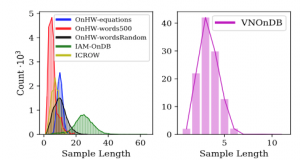
Benchmarking Online Sequence-to-Sequence and Character-based Handwriting Recognition from IMU-enhanced Pens
We present data and benchmark models . We propose a variety of datasets including equations and words for both the writer-dependent and writer-independent real-time sequence-to-sequence (seq2seq) learning and single character-based recognition. We provide an evaluation benchmark for the seq2seq and single character-based HWR using recurrent and temporal convolutional networks and Transformers combined with a connectionist temporal classification (CTC) loss. Our methods do not resort to language or lexicon models.
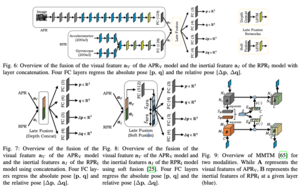
Benchmarking visual-inertial deep multimodal fusion for relative pose regression and odometry-aided absolute pose regression
Visual-inertial localization is a key problem in computer vision and robotics applications such as virtual reality, self-driving cars, and aerial vehicles. The goal is to estimate an accurate pose of an object when either the environment or the dynamics are known. Absolute pose regression (APR) techniques directly regress the absolute pose from an image input in a known scene using convolutional and spatio-temporal networks. Odometry methods perform relative pose regression (RPR) that predicts the relative pose from a known object dynamic (visual or inertial inputs). The localization task can be improved by retrieving information from both data sources for a cross-modal setup, which is a challenging problem due to contradictory tasks. In this work, we conduct a benchmark to evaluate deep multimodal fusion based on pose graph optimization and attention networks. Auxiliary and Bayesian learning are utilized for the APR task. We show accuracy improvements for the APR-RPR task and for the RPR-RPR task for aerial vehicles and hand-held devices. We conduct experiments on the EuRoC MAV and PennCOSYVIO datasets and record and evaluate a novel industry dataset.
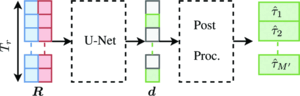
Delay Estimation in Dense Multipath Environments using Time Series Segmentation
We propose a pipeline built upon the U-Net convolutional neural network architecture. Unlike the state of the art our pipeline extracts an arbitrary number of delays without prior knowledge, includes a threshold for weighting between detection rate and false alarms, and does not rely on computationally demanding operations such as eigenvalue decomposition. We evaluate the presented method with synthetic data of different noise configurations and signal bandwidths and a publicly available dataset, achieving considerable performance gains w.r.t. detection performance and tracking accuracy. Furthermore, we show that the proposed method is far less computationally demanding in inference.
Domain Adaptation for Time-Series Classification to Mitigate Covariate Shift
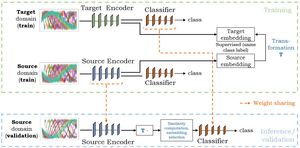
We propose a novel supervised DA based on two steps. First, we search for an optimal class-dependent transformation from the source to the target domain from a few samples. We consider optimal transport methods such as the earth mover’s distance, Sinkhorn transport and correlation alignment. Second, we use embedding similarity techniques to select the corresponding transformation at inference. We use correlation metrics and higher-order moment matching techniques.
Driver Dojo: A Benchmark for Generalizable Reinforcement Learning for Autonomous Driving
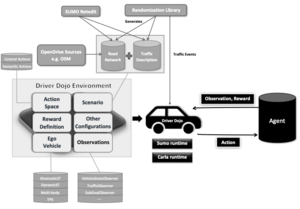
We propose a challenging benchmark for generalizable RL for AD based on a configurable, flexible, and performant code base. Our benchmark uses a catalog of randomized scenario generators, including multiple mechanisms for road layout and traffic variations, different numerical and visual observation types, distinct action spaces, diverse vehicle models, and allows for use under static scenario definitions. In addition to purely algorithmic insights, our application-oriented benchmark also enables a better understanding of the impact of design decisions such as action and observation space on the generalizability of policies. Our benchmark aims to encourage researchers to propose solutions that are able to successfully generalize across scenarios, a task in which current RL methods fail.
Code available here: https://github.com/seawee1/driver-dojo