Selected Publications

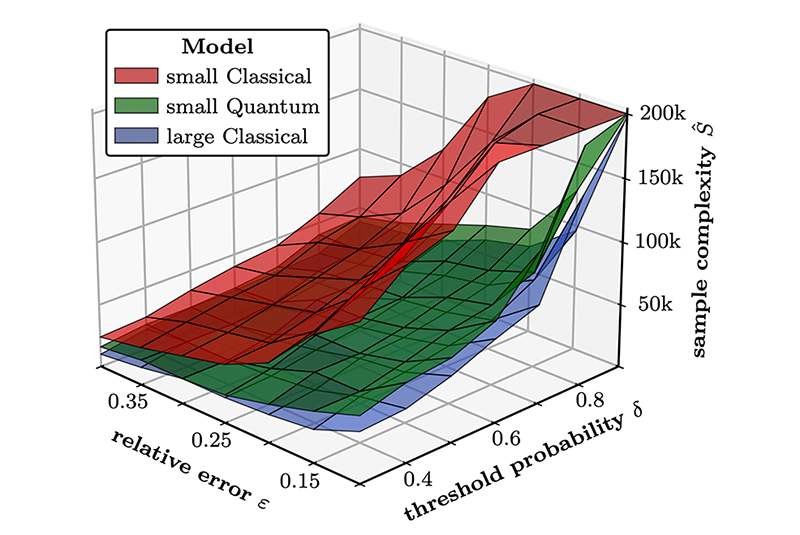


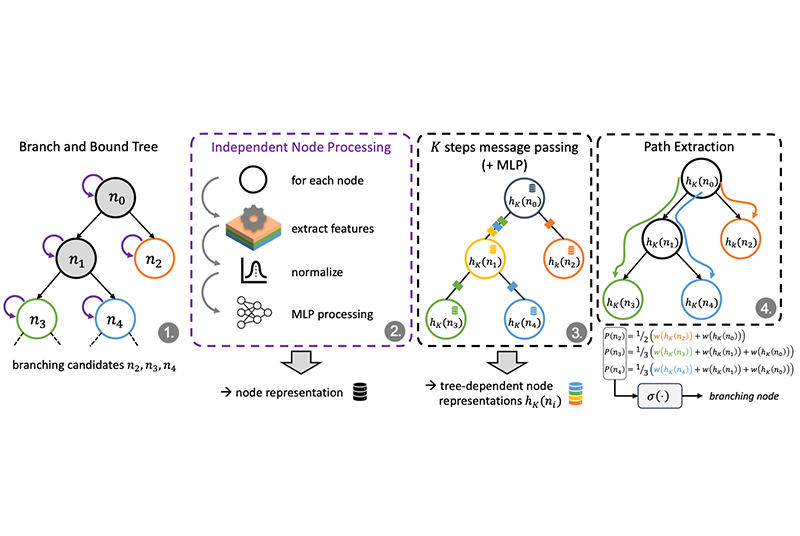
All Publications
Passive Channel Charting: Locating Passive Targets using a UWB Mesh
Fingerprint-based passive localization enables high localization accuracy using low-cost UWB IoT radio sensors. However, fingerprinting demands extensive effort for data acquisition. The concept of channel charting reduces this effort by modeling and projecting the manifold of channel state information (CSI) onto a 2D coordinate space. So far, researchers have only applied this concept to active radio localization, where a mobile device intentionally and actively emits a specific signal.In this paper, we apply channel charting to passive localization. We use a pedestrian dead reckoning (PDR) system to estimate a target’s velocity and derive a distance matrix from it. We then use this matrix to learn a distance-preserving embedding in 2D space, which serves as a fingerprinting model. In our experiments, we deploy six nodes in a fully connected ultra-wideband (UWB) mesh network to show that our method achieves high localization accuracy, with an average error of just 0.24 m, even when we train and test on different targets.
Resilient Channel Charting Under Varying Radio Link Availability
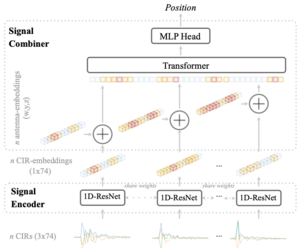
We show a channel charting architecture that can natively handle variable numbers of CSI measurements and arbitrary antenna subsets. Across two public real-world SISO and MIMO datasets, AdaPos maintains state-of-the-art localization accuracy under missing-antenna conditions, replaces roughly 57 configuration-specific models with a single unified model, and provides resilience to both individual antenna failures and full-array outages.
Rethinking AI/ML for Air Interface in Wireless Networks
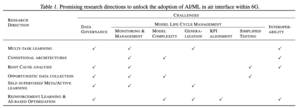
We provide an overview of AI/ML-related discussions in 3GPP standardization, highlighting key use cases, architectural considerations, and technical requirements. We outline open research challenges and opportunities where academic and industrial communities can contribute to shaping the future of AI-enabled wireless systems.
Simplicity is Key: An Unsupervised Pretraining Approach for Sparse Radio Channels
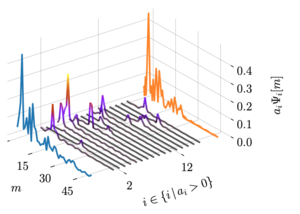
We introduce Sparse pretrained Radio Transformer (SpaRTran), a hybrid method based on the concept of compressed sensing for wireless channels. SpaRTran builds around a wireless channel model that constrains the optimization procedure to physically meaningful solutions and induces a strong inductive bias, cutting positioning error by up to 28% and increasing top-1 codebook selection accuracy for beamforming by 26 percentage points.
Variational Quantum Error Correction
Quantum error correction is critical for protecting quantum computations from noise, yet standard protocols demand significant qubit overhead. To address this, we introduce a learning-based approach that allows tailoring encodings to specific noise channels. This approach is based on a novel loss function that maximizes the distinguishability of noisy quantum states. We thereby realize a variational quantum algorithm that discovers new resource-efficient codes, which empirically outperform standard quantum error correction schemes on various noise structures. We furthermore derive promising theoretical properties of these variational quantum error correction (VarQEC) codes and perform proof-of-concept experiments on quantum hardware.
BCQQ: Batch-Constraint Quantum Q-Learning with Cyclic Data Re-uploading
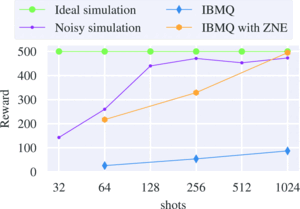
In this paper, we investigate this potential advantage by proposing a batch RL algorithm that utilizes variational quantum circuits (VQCs) as function approximators within the discrete batch-constraint deep Q-learning (BCQ) algorithm. Additionally, we introduce a novel data re-uploading scheme by cyclically shifting the order of input variables in the data encoding layers. We evaluate the efficiency of our algorithm on the OpenAI CartPole environment and compare its performance to the classical neural network-based discrete BCQ.
C-MCTS: Safe Planning with Monte Carlo Tree Search
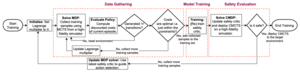
The Constrained Markov Decision Process (CMDP) formulation allows to solve safety-critical decision making tasks that are subject to constraints. While CMDPs have been extensively studied in the Reinforcement Learning literature, little attention has been given to sampling-based planning algorithms such as MCTS for solving them. Previous approaches perform conservatively with respect to costs as they avoid constraint violations by using Monte Carlo cost estimates that suffer from high variance. We propose Constrained MCTS (C-MCTS), which estimates cost using a safety critic that is trained with Temporal Difference learning in an offline phase prior to agent deployment. The critic limits exploration by pruning unsafe trajectories within MCTS during deployment. C-MCTS satisfies cost constraints but operates closer to the constraint boundary, achieving higher rewards than previous work. As a nice byproduct, the planner is more efficient w.r.t. planning steps. Most importantly, under model mismatch between the planner and the real world, C-MCTS is less susceptible to cost violations than previous work.
Comprehensive Library of Variational LSE Solvers
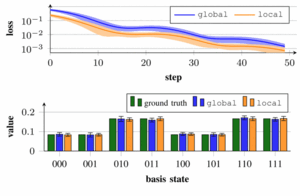
Linear systems of equations can be found in various mathematical domains, as well as in the field of machine learning. By employing noisy intermediate-scale quantum devices, variational solvers promise to accelerate finding solutions for large systems. Although there is a wealth of theoretical research on these algorithms, only fragmentary implementations exist. To fill this gap, we have developed the variational-lse-solver framework, which realizes existing approaches in literature, and introduces several enhancements. The user-friendly interface is designed for researchers that work at the abstraction level of identifying and developing end-to-end applications.
Estimating Multipath Component Delays with Transformer Models
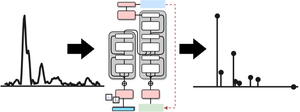
We implicitly estimate the number of MPCs and achieve subsample accuracy without using computationally intensive super-resolution techniques. Our approach outperforms known methods in detection performance and accuracy at different bandwidths. Our ablation study shows exceptional results on simulated and real datasets and generalizes to unknown radio environments.
Few-shot learning with uncertainty-based quadruplet selection for interference classification in GNSS data
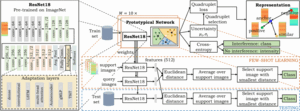
We propose a few-shot learning (FSL) approach to adapt to new interference classes. Our method employs quadruplet selection for the model to learn representations using various positive and negative interference classes. Furthermore, our quadruplet vari-ant selects pairs based on the aleatoric and epistemic uncertainty to differentiate between similar classes. We recorded a dataset at a motorway with eight interference classes on which our FSL method with quadruplet loss outperforms other FSL techniques in jammer classification accuracy with 97.66%. https://gitlab.cc-asp.fraunhofer.de/darcy_gnsslFIOT_highway.
Fusing Structure from Motion and Simulation-augmented Pose Regression from Optical Flow for Challenging Indoor Environments
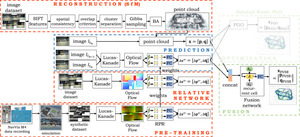
We enhance the performance of SfM and PoseNet in retrieving absolute poses, evaluate PGO to optimize the absolute pose and conduct a benchmark of 25 convolutional, recurrent, and Transformer networks in absolute and relative pose fusion.
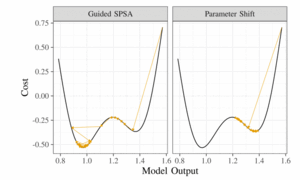
Guided-SPSA: Simultaneous Perturbation Stochastic Approximation assisted by the Parameter Shift Rule
We introduce a novel gradient estimation approach called Guided-SPSA, which meaningfully combines the parameter-shift rule and SPSA-based gradient approximation. We demonstrate numerically the performance of Guided-SPSA on different paradigms of quantum machine learning, such as regression, classification, and reinforcement learning.
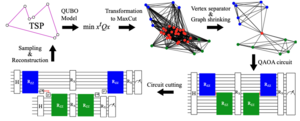
Improving quantum and classical decomposition methods for vehicle routing
We demonstrate the utility of our novel shrinking method by successfully applying it to the archetypical traveling salesperson problem (TSP) which often occurs as a sub-problem in practically relevant vehicle routing applications. For a TSP with seven cities, we are able to retrieve an optimum solution by consecutively running two 7-qubit QAOA circuits. Without decomposition methods, we would require five times as many qubits. Our results offer insights into the performance of algorithms for combinatorial optimization problems within the constraints of current quantum technology.
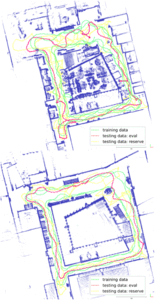
Offsite evaluation of localization systems: criteria, systems and results from IPIN 2021-22 competitions
The main contribution of this work is to show a compilation of possible indoor positioning scenarios and different indoor positioning solutions to the same problem.
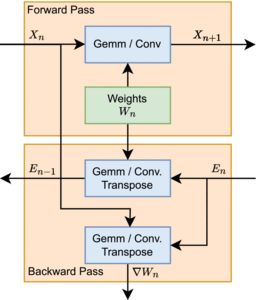
On-Device Training of Fully Quantized Deep Neural Networks on Cortex-M Microcontrollers
We present a method that enables efficient training of DNNs completely in place on the MCU using fully quantized training (FQT) and dynamic partial gradient updates. We demonstrate the feasibility of our approach on multiple vision and time-series datasets and provide insights into the tradeoff between training accuracy, memory overhead, energy, and latency on real hardware. The results show that compared to related work, our approach requires 34.8% less memory and has a 49.0% lower latency per training sample, with dynamic partial gradient updates allowing a speedup of up to 8.7 compared to fully updating all weights.